Offline Programming and Collision Simulation for 3D Five-Axis Laser Cutting
-
September 8, 2026

-
24 min read

Programming a conventional flat-sheet laser cutter is relatively straightforward.
The workpiece is flat.
The cutting head normally remains perpendicular to the sheet.
And most cutting paths exist in a two-dimensional X-Y plane.
A 3D five-axis laser cutting machine creates a very different programming problem.
The cutting head may need to:
At the same time, the programmer must consider:
This is why offline programming and collision simulation are so important in 3D laser cutting.
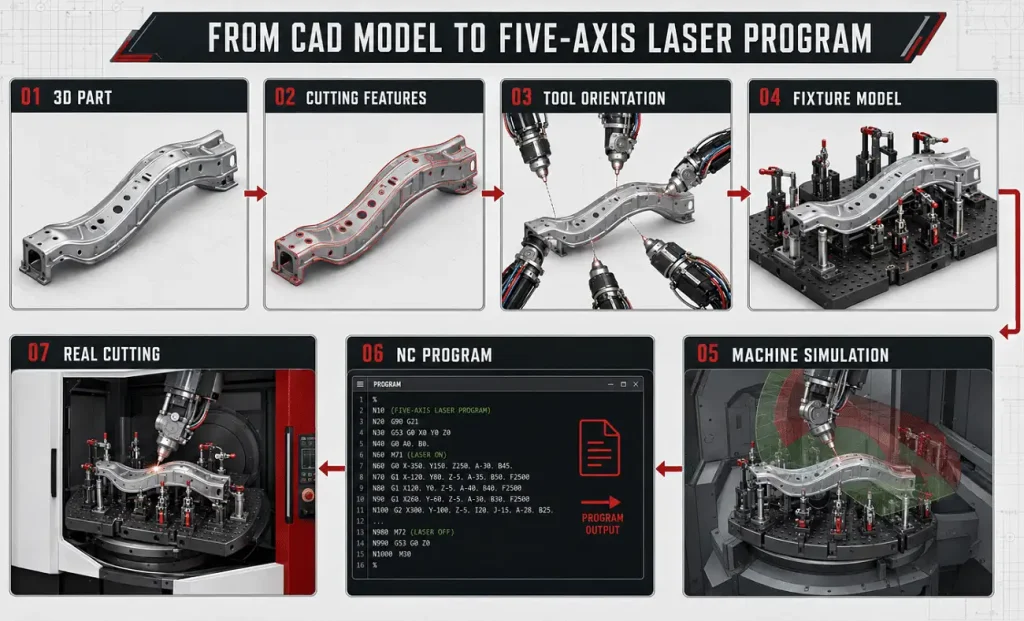
TRUMPF’s current TruTops Cell software is designed specifically for offline 3D laser processing. It supports CAD import, fixture programming, NC generation, path optimization and collision checking before the program reaches the machine.
The objective is not simply to create a cutting path.
It is to create a program that is:
geometrically correct + physically reachable + collision-free + process-capable + efficient to execute.
Offline programming means creating and validating the laser processing program on a separate computer rather than developing the entire program directly at the machine.
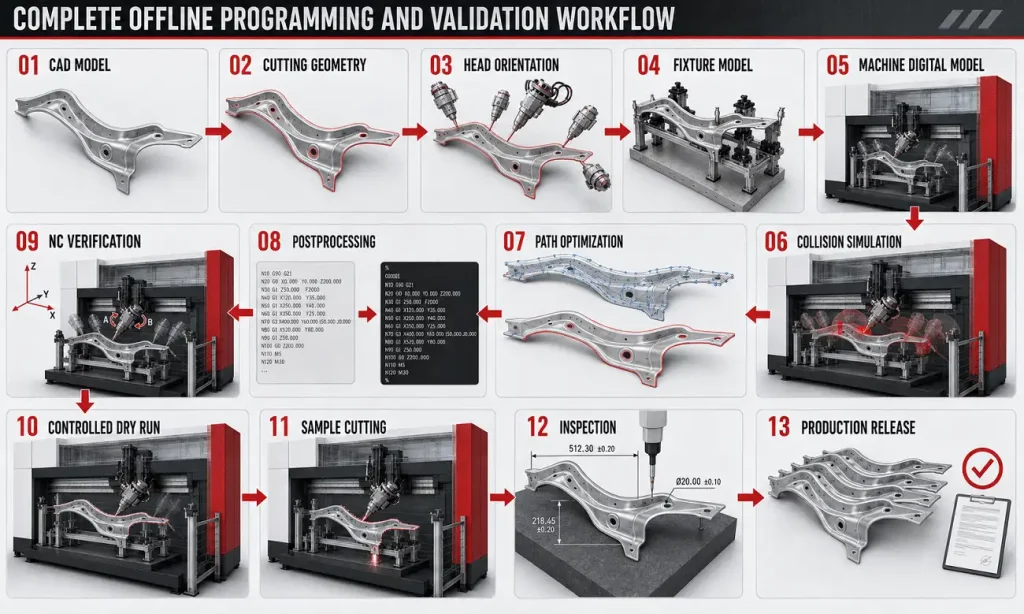
A typical workflow is:
3D CAD Model
→ Define Cutting Geometry
→ Generate Cutting Path
→ Set Cutting-Head Orientation
→ Add Fixture and Machine Model
→ Simulate Five-Axis Motion
→ Check Collisions
→ Optimize Sequence
→ Generate NC Program
→ Transfer to Machine
The biggest production advantage is that programming can happen while the machine continues processing other jobs.
TRUMPF specifically describes this parallel programming as one of the main benefits of 3D offline programming: new programs can be created while production continues rather than occupying the real machine for programming work.
The software creates the digital production program.
The real machine still requires:
Offline programming reduces machine-side engineering time.
It does not remove the need for safe commissioning.
In 2D cutting, most movement is easy to predict.
A head moves above a flat sheet.
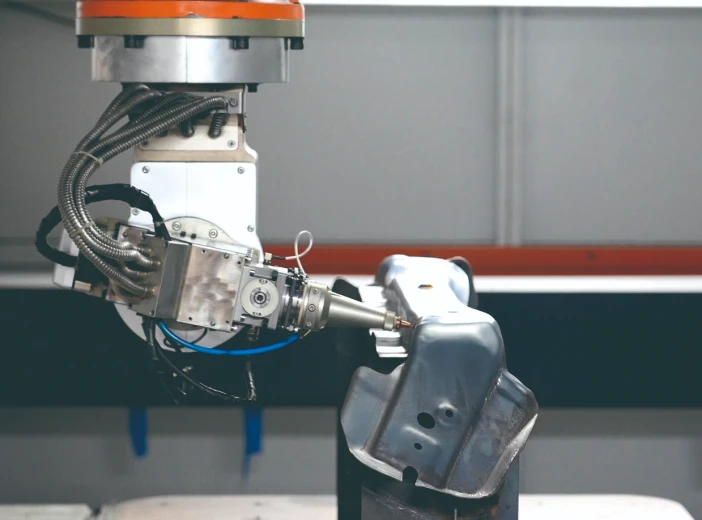
In five-axis cutting, changing tool orientation changes the space occupied by the entire cutting head.
A programmed point may be reachable by the laser beam but not by the physical cutting head.
For example:
The nozzle may reach a hole correctly.
But when the head tilts 55°, the upper cutting-head body may collide with:
This creates an important principle:
Laser accessibility is not the same as cutting-head accessibility.
The complete three-dimensional cutting head must be evaluated.
Every reliable offline program starts with correct geometry.
Before programming, confirm:
This sounds obvious, but engineering revisions are a major practical risk.
A customer may send:
If the programmer uses an outdated CAD file, collision simulation may be perfect while the actual component is wrong.
The programming record should identify:
This becomes particularly important when multiple automotive variants share similar fixtures.
The complete CAD model tells the software what the component looks like.
But the programmer must still determine what should actually be cut.
Typical processing geometry includes:
Some CAD edges may represent:
rather than laser-cut contours.
The cutting geometry should therefore be derived from:
not merely visible CAD edges.
The virtual part must correspond to the real part on the fixture.
Typical coordinate relationships include:
Machine Coordinate System
↓
Fixture Coordinate System
↓
Workpiece Coordinate System
↓
CAD / CAM Program
If this relationship is wrong, the program can be internally correct but applied at the wrong physical location.
Typical symptoms include:
Coordinate setup is therefore part of programming—not merely machine setup.
3D five-axis laser cutting accuracy
The workpiece alone is not enough.
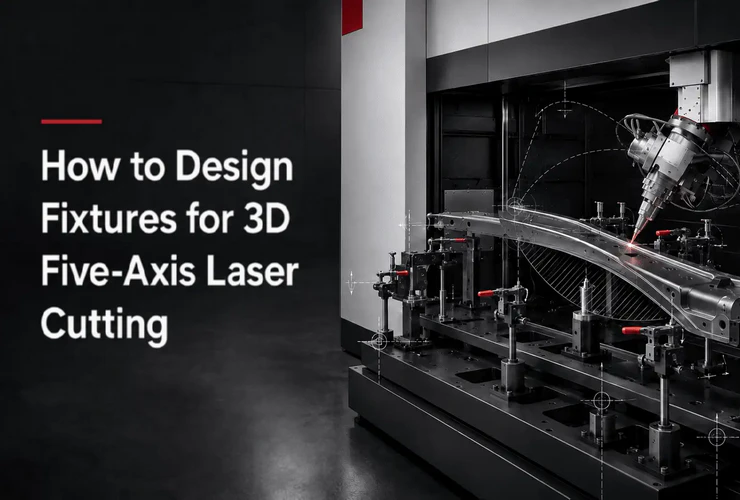
The fixture should be represented digitally.
Include:
The recently published ZG Laser fixture-design article makes this same point: every locator, support and clamp should be evaluated against the complete cutting-head movement envelope.
Do not simplify a pneumatic clamp into a small block if the actual clamp has:
That “unimportant” geometry may become the real collision point.
Collision simulation should not use only a laser axis line.
The digital head model should include the collision-relevant geometry of:
Where relevant, also consider:
The more accurately the digital model represents the real machine, the more useful collision simulation becomes.
This reflects the wider principle used in modern multi-axis CAM simulation: Siemens recommends realistic machine models including kinematics, fixtures and tooling when validating programs and detecting collisions.
For each point on a 3D cutting path, the programmer must decide:
From what direction should the laser head approach the surface?
The theoretically simple choice is to align the laser beam with the local surface normal.
But real production may require modifying that orientation.
Reasons include:
It can influence:
The best orientation is therefore a compromise between:
geometry + cutting process + machine kinematics.
Five-axis capability does not mean the head should constantly rotate.
Excessive rotary motion may:
Where possible, the programmer should seek smooth orientation changes.
A good five-axis program does not merely reach every point.
It reaches every point efficiently and predictably.
Every five-axis head has a defined rotary working range.
The program must stay inside it.
A path can therefore be geometrically valid but impossible for the real machine.
Potential issues include:
Simulation should identify these conditions before machine execution.
ZG Laser’s current five-axis equipment positioning explicitly combines offline programming with five-axis control for complex 3D geometries, making machine-specific motion verification an important part of the programming process.
In simultaneous multi-axis movement, the controller must coordinate several possible axis positions to produce the requested tool orientation.
Certain geometries may create difficult transitions where rotary axes:
These should be identified during simulation.
Siemens notes that five-axis simulation needs to represent the actual machine kinematics and controller behavior because the kinematic solution used by the controller affects collision risk and real machine movement.
This is why inspecting only the laser-point trajectory is insufficient.
Where software allows, review:
The finished contour itself may be collision-free.
The approach to that contour may not be.
Programming should include:
Avoid placing piercing where it can:
After finishing a contour, the cutting head must safely leave the part.
Do not assume the reverse of the approach path is always the best retract path.
This is one of the most important programming rules.
The cutting path may be perfectly safe while the rapid movement between two cutting features causes a collision.
For example:
Therefore simulate:
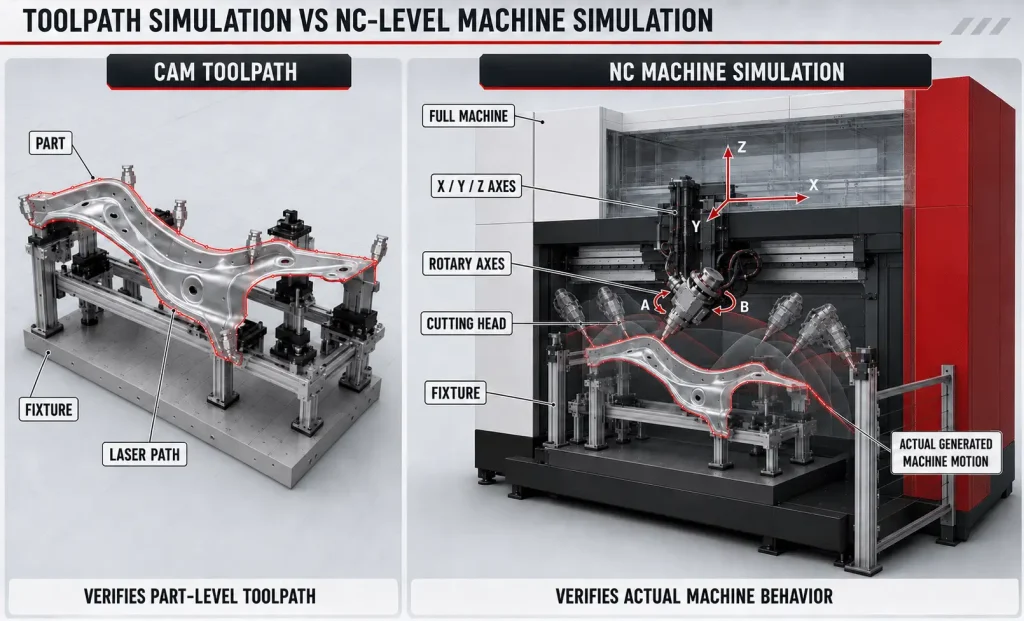
Modern NC-level simulation is valuable specifically because movements introduced after CAM path creation can also be checked. Siemens distinguishes toolpath simulation from G-code-driven simulation and notes that postprocessed NC simulation can include additional machine motions generated by the postprocessor.
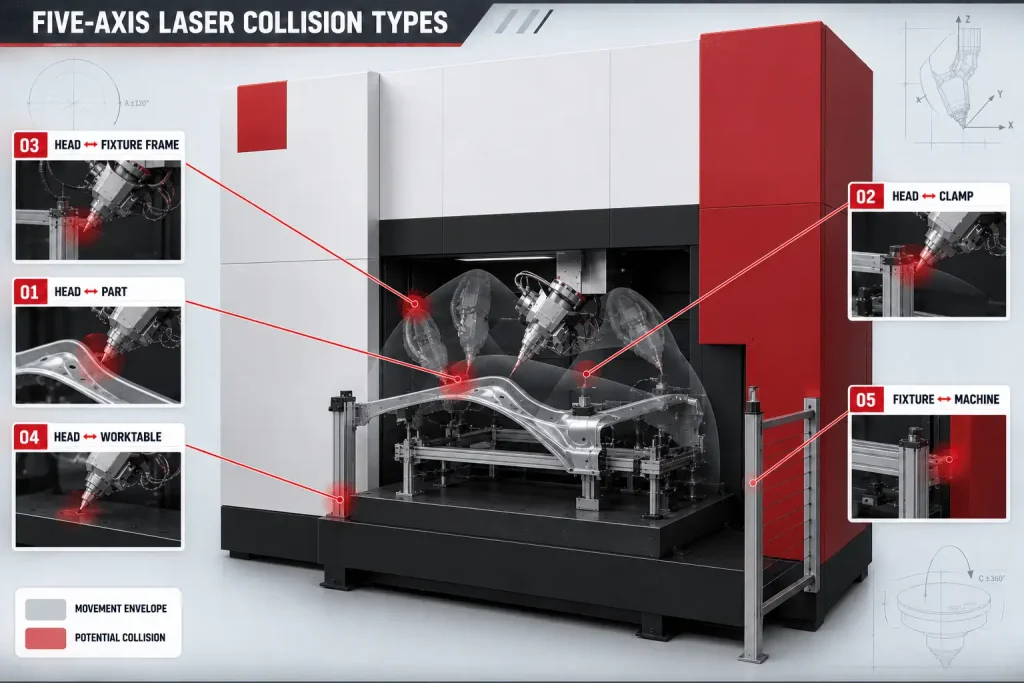
A complete five-axis simulation should evaluate several collision pairs.
Especially:
Including:
Particularly around:
Depending on machine layout:
Especially when using:
Large parts may extend into restricted areas during table movement.
Checking the head at several individual positions is useful but may miss collisions between those positions.
A stronger engineering method is to consider the swept envelope of the head.
This represents the complete volume occupied while the head travels through a movement.
It is particularly useful around:
This concept also connects directly with fixture design.
If the fixture intersects the required swept envelope, the engineering team may need to:
When simulation finds a collision, the first reaction should not always be:
“Move the cutting path.”
The trim path is usually defined by the part drawing.
Instead, evaluate possible changes in this order:
The finished geometry should only change when engineering allows it.
This is why fixture design and programming should be developed together rather than sequentially.
The order in which features are processed affects:
A program might include:
For some formed parts:
This can help prevent the part from losing stiffness too early.
The exact sequence should be verified on real parts.
Collision simulation often focuses on the original component.
But the geometry changes during cutting.
A removed slug or trimmed flange may:
Static CAD simulation may not perfectly predict the behavior of loose scrap.
This is one reason controlled first-part verification remains necessary even after successful digital simulation.
The cutting-head angle affects where sparks and molten metal travel.
Avoid directing slag toward:
Programming and fixture engineering should therefore consider the direction of material ejection.
Sometimes a small change in:
can improve fixture protection.
Geometry alone is not enough.
The program may also assign process conditions for different features.
These can include:
TRUMPF’s offline programming approach combines geometric programming with integrated processing technology and standard parameters rather than treating them as completely separate workflows.
For example:
may not necessarily use identical process conditions.
A head may avoid collision but still have poor process geometry.
Examples:
Therefore simulation should ask two separate questions:
Can the head physically reach the feature?
and:
Can the process cut the feature correctly from that orientation?
That distinction is important for:
Collision simulation depends on the accuracy of the virtual environment.
The model should correspond to the actual:
Siemens refers to this concept as using a realistic virtual machine or digital twin containing the actual machine kinematics, which improves collision checking and NC program validation.
Two five-axis machines may differ in:
A path safe on one machine may not be safe on another.
CAM software creates a toolpath.
The machine controller executes an NC program.
The postprocessor converts the programmed operation into machine-specific NC instructions.
This step may affect:
For this reason, advanced validation can go beyond the internal CAM trajectory and simulate the postprocessed NC program.
Siemens specifically describes G-code-driven simulation as a way of validating the motion generated from NC output, including content added by the postprocessor.
When evaluating software, ask:
Is the simulation based on the CAM path, or can it validate the actual postprocessed machine program?
Both can be useful.
They are not identical.
This distinction is worth explaining clearly.
Shows the intended CAM movement.
Useful for:
Uses postprocessed machine instructions.
Potentially checks:
Siemens provides both levels and describes G-code-driven simulation as the higher-fidelity approach for verifying actual CNC execution.
For an industrial five-axis laser project, the buyer should understand what level of verification the supplied programming package actually provides.
Collision avoidance is only one goal.
Offline programming can also help optimize production efficiency.
Compare:
TRUMPF includes path optimization within its offline programming workflow, while modern virtual-machine solutions can also support production-time estimation before physical production begins.
Instead of:
Feature A
→ long retract
→ major head rotation
→ Feature B
→ opposite side
→ Feature C
a better sequence may group features according to:
The shortest geometric path is not always the fastest path if it requires excessive rotary-axis movement.
A dangerous path that is two seconds faster is not an optimized path.
Program optimization should normally follow this priority:
Once the process is safe and stable, optimize unnecessary motion.
Automotive hot-formed components often contain:
Typical examples include:
The article already published on ZG Laser’s site describes the same workflow: importing the 3D model, defining the trim path, designing the fixture, establishing coordinates and simulating complete motion before cutting.
Laser trimming of hot-formed automotive parts
The virtual system assumes that the real machine corresponds to the digital model.
If the actual machine has:
then a perfectly simulated program can still produce an inaccurate part.
Therefore simulation and calibration solve different problems.
Can the programmed movement safely and correctly occur?
Does the real machine physically execute that movement where the digital model expects?
Both are required.
Five-axis laser cutting calibration and accuracy
After fixture manufacturing, compare it with the digital model.
Check:
A fixture may be modified during assembly.
For example:
If these changes are not updated in the simulation model, future programs may contain hidden collision risks.
Recommended record:
Fixture ID: BP-01
Digital Model: Rev C
Physical Fixture: Rev C
NC Program: Rev 05
Part CAD: Rev F
Digital and physical configuration should remain synchronized.
Passing offline collision simulation is not permission to run an unfamiliar program at full speed immediately.
A controlled first-run procedure may include:
The exact commissioning procedure should follow the machine manufacturer’s safety and operating requirements.
Simulation cannot perfectly predict:
Offline programming dramatically reduces risk.
It does not turn physical commissioning into an unnecessary step.
These two tests answer different questions.
Primarily evaluates:
Evaluates:
Both may be useful for difficult new parts.
| Problem | Likely Cause | First Check |
|---|---|---|
| Head collides with clamp | Fixture not modeled accurately | Compare digital and physical fixture |
| Path works in CAM but not machine | Postprocessor or machine model mismatch | Validate NC output |
| Rotary axis reaches limit | Poor head orientation | Re-optimize orientation |
| Excessive axis rotation | Unoptimized kinematic transition | Review axis motion |
| Nozzle reaches part but head collides | Only beam/nozzle was checked | Use full head model |
| Collision during rapid movement | Only cutting path simulated | Simulate non-cutting moves |
| Program shifted on real part | Coordinate mismatch | Fixture/workpiece zero |
| Safe simulation but inaccurate cut | Calibration/TCP issue | Verify machine calibration |
| Slug hits head | Scrap behavior not considered | Review sequence and clearance |
| Gas performance poor on angled feature | Orientation unsuitable | Review head angle and nozzle geometry |
| Cycle time too long | Excessive rapid/head rotation | Optimize sequence |
| Old program used | Weak revision control | Program management system |
A robust project can follow this sequence.
Collect:
Select:
Match the CAD coordinate system with the fixture strategy.
Set:
Balance:
Include all relevant geometry.
Include the actual:
Check:
Reduce:
Define appropriate:
Use the correct machine-specific postprocessor.
Where supported, run full machine / NC simulation.
Verify correct:
Verify real-world movement.
Measure:
The final production program should incorporate validated corrections.
Once production starts, the program becomes a controlled manufacturing asset.
Do not save files as:
Bpillar-final.nc
Bpillar-final2.nc
Bpillar-new-final.nc
Bpillar-really-final.nc
Use a structured system.
For example:
Part: BP-RH
Part Revision: F
Fixture: BP-RH-02 Rev C
Program: BP-RH-F-P07
Parameter Set: PHS15-04
Released: 2026-08-xx
Record why revisions changed.
Examples:
This reduces the risk of producing the correct part with the wrong revision.
For repeated production, retain:
The goal is to make the process reproducible rather than dependent on one programmer’s memory.
When purchasing a five-axis machine, do not accept:
“Software included.”
Ask what that actually means.
Not every software package provides the same level of functionality.
TRUMPF’s current solution, for example, combines CAD import, device/fixture work, programming, optimization and collision checking in one 3D laser workflow; that is useful as a benchmark for understanding what a mature offline-programming workflow can contain.
Software should be evaluated alongside the mechanical machine.
Imagine two machines with similar:
but very different programming environments.
Machine A allows:
Machine B requires most complex adjustment directly at the machine.
For high-mix 3D production, the software difference can significantly affect:
Therefore:
The programming environment is part of the five-axis machine capability.
The priorities change with production type.
Important factors:
Important factors:
The same software may serve both, but the production workflow should be different.
Both use 3D offline programming, but the kinematics are different.
Simulation focuses on:
Simulation must additionally consider:
The programming philosophy is related, but the motion platform creates different risks.
Before releasing a program, confirm:
Offline programming is not simply a convenient way to create a five-axis laser cutting path.
It is part of the engineering process that connects:
CAD geometry → fixture → machine kinematics → laser process → real production.
A reliable offline program should answer five questions:
This is why collision simulation should include much more than the laser line.
It should represent:
And where high-level verification is required, validating the postprocessed machine program with a realistic machine model provides another layer beyond basic CAM path visualization. This same distinction between toolpath checking and NC-driven digital-machine simulation is emphasized by modern multi-axis manufacturing systems.
Most importantly:
A collision-free simulation reduces risk, but it does not eliminate controlled real-machine validation.
The strongest production workflow combines:
offline programming + accurate fixture model + machine simulation + calibration + controlled first run + sample inspection
before production release.
Send ZG Laser:
Our application team can evaluate:
before final production configuration.
Send Your 3D Drawing for Evaluation
Explore 3D Five-Axis Laser Cutting Machines
Offline programming means creating and verifying the 3D cutting program on a separate computer rather than developing the entire program directly at the machine. It can include CAD import, toolpath generation, head orientation, fixture modeling, simulation and NC generation.
The cutting head changes orientation around three-dimensional components. A path that is reachable by the laser beam may still cause the cutting-head body to collide with the workpiece, fixture or machine.
A useful simulation should include the workpiece, complete cutting head, fixture, clamps, worktable and relevant machine structure. Cutting moves, rapid moves, approaches and retracts should all be evaluated.
No. Toolpath simulation normally verifies the CAM-generated movement. NC or G-code simulation uses the postprocessed machine program and can more closely represent the instructions that the machine controller will execute. Siemens distinguishes these levels in its current machine-simulation solutions.
No. Simulation reduces risk, but its accuracy depends on the digital models, coordinate setup, postprocessor and real machine condition. Physical fixture changes, part variation and loose scrap can also create conditions not perfectly represented virtually.
Yes. Clamps, locators and supports are common collision risks and should be represented as accurately as practical.
A program can have a collision-free cutting path but collide while repositioning between two features. Non-cutting movement should therefore be included in verification.
It can. The programmer can optimize cutting sequence, rapid movements and cutting-head orientation before production. TRUMPF specifically includes collision checking and path optimization in its offline 3D programming workflow.
It should not be treated as a universal replacement for controlled first-program verification. A real machine may differ from the digital environment due to calibration, fixture changes, part variation or other physical conditions.
The postprocessor converts CAM operations into machine-specific NC instructions. Incorrect postprocessing can create motion different from the intended CAM path.
Yes. Incorrect coordinates, head orientation, geometry or program revision can create systematic cutting errors even when the machine itself is mechanically accurate.
Not automatically. Machines may use different kinematics, rotary-axis ranges, cutting heads, controllers and postprocessors. The program should be configured and validated for the specific machine.

English

French

German

Hindi

Italian

Japanese

Korean

Portuguese

Russian

Spanish
Tell us about your manufacturing challenges.
Our engineers will design a laser solution tailored to your exact requirements.